The Work
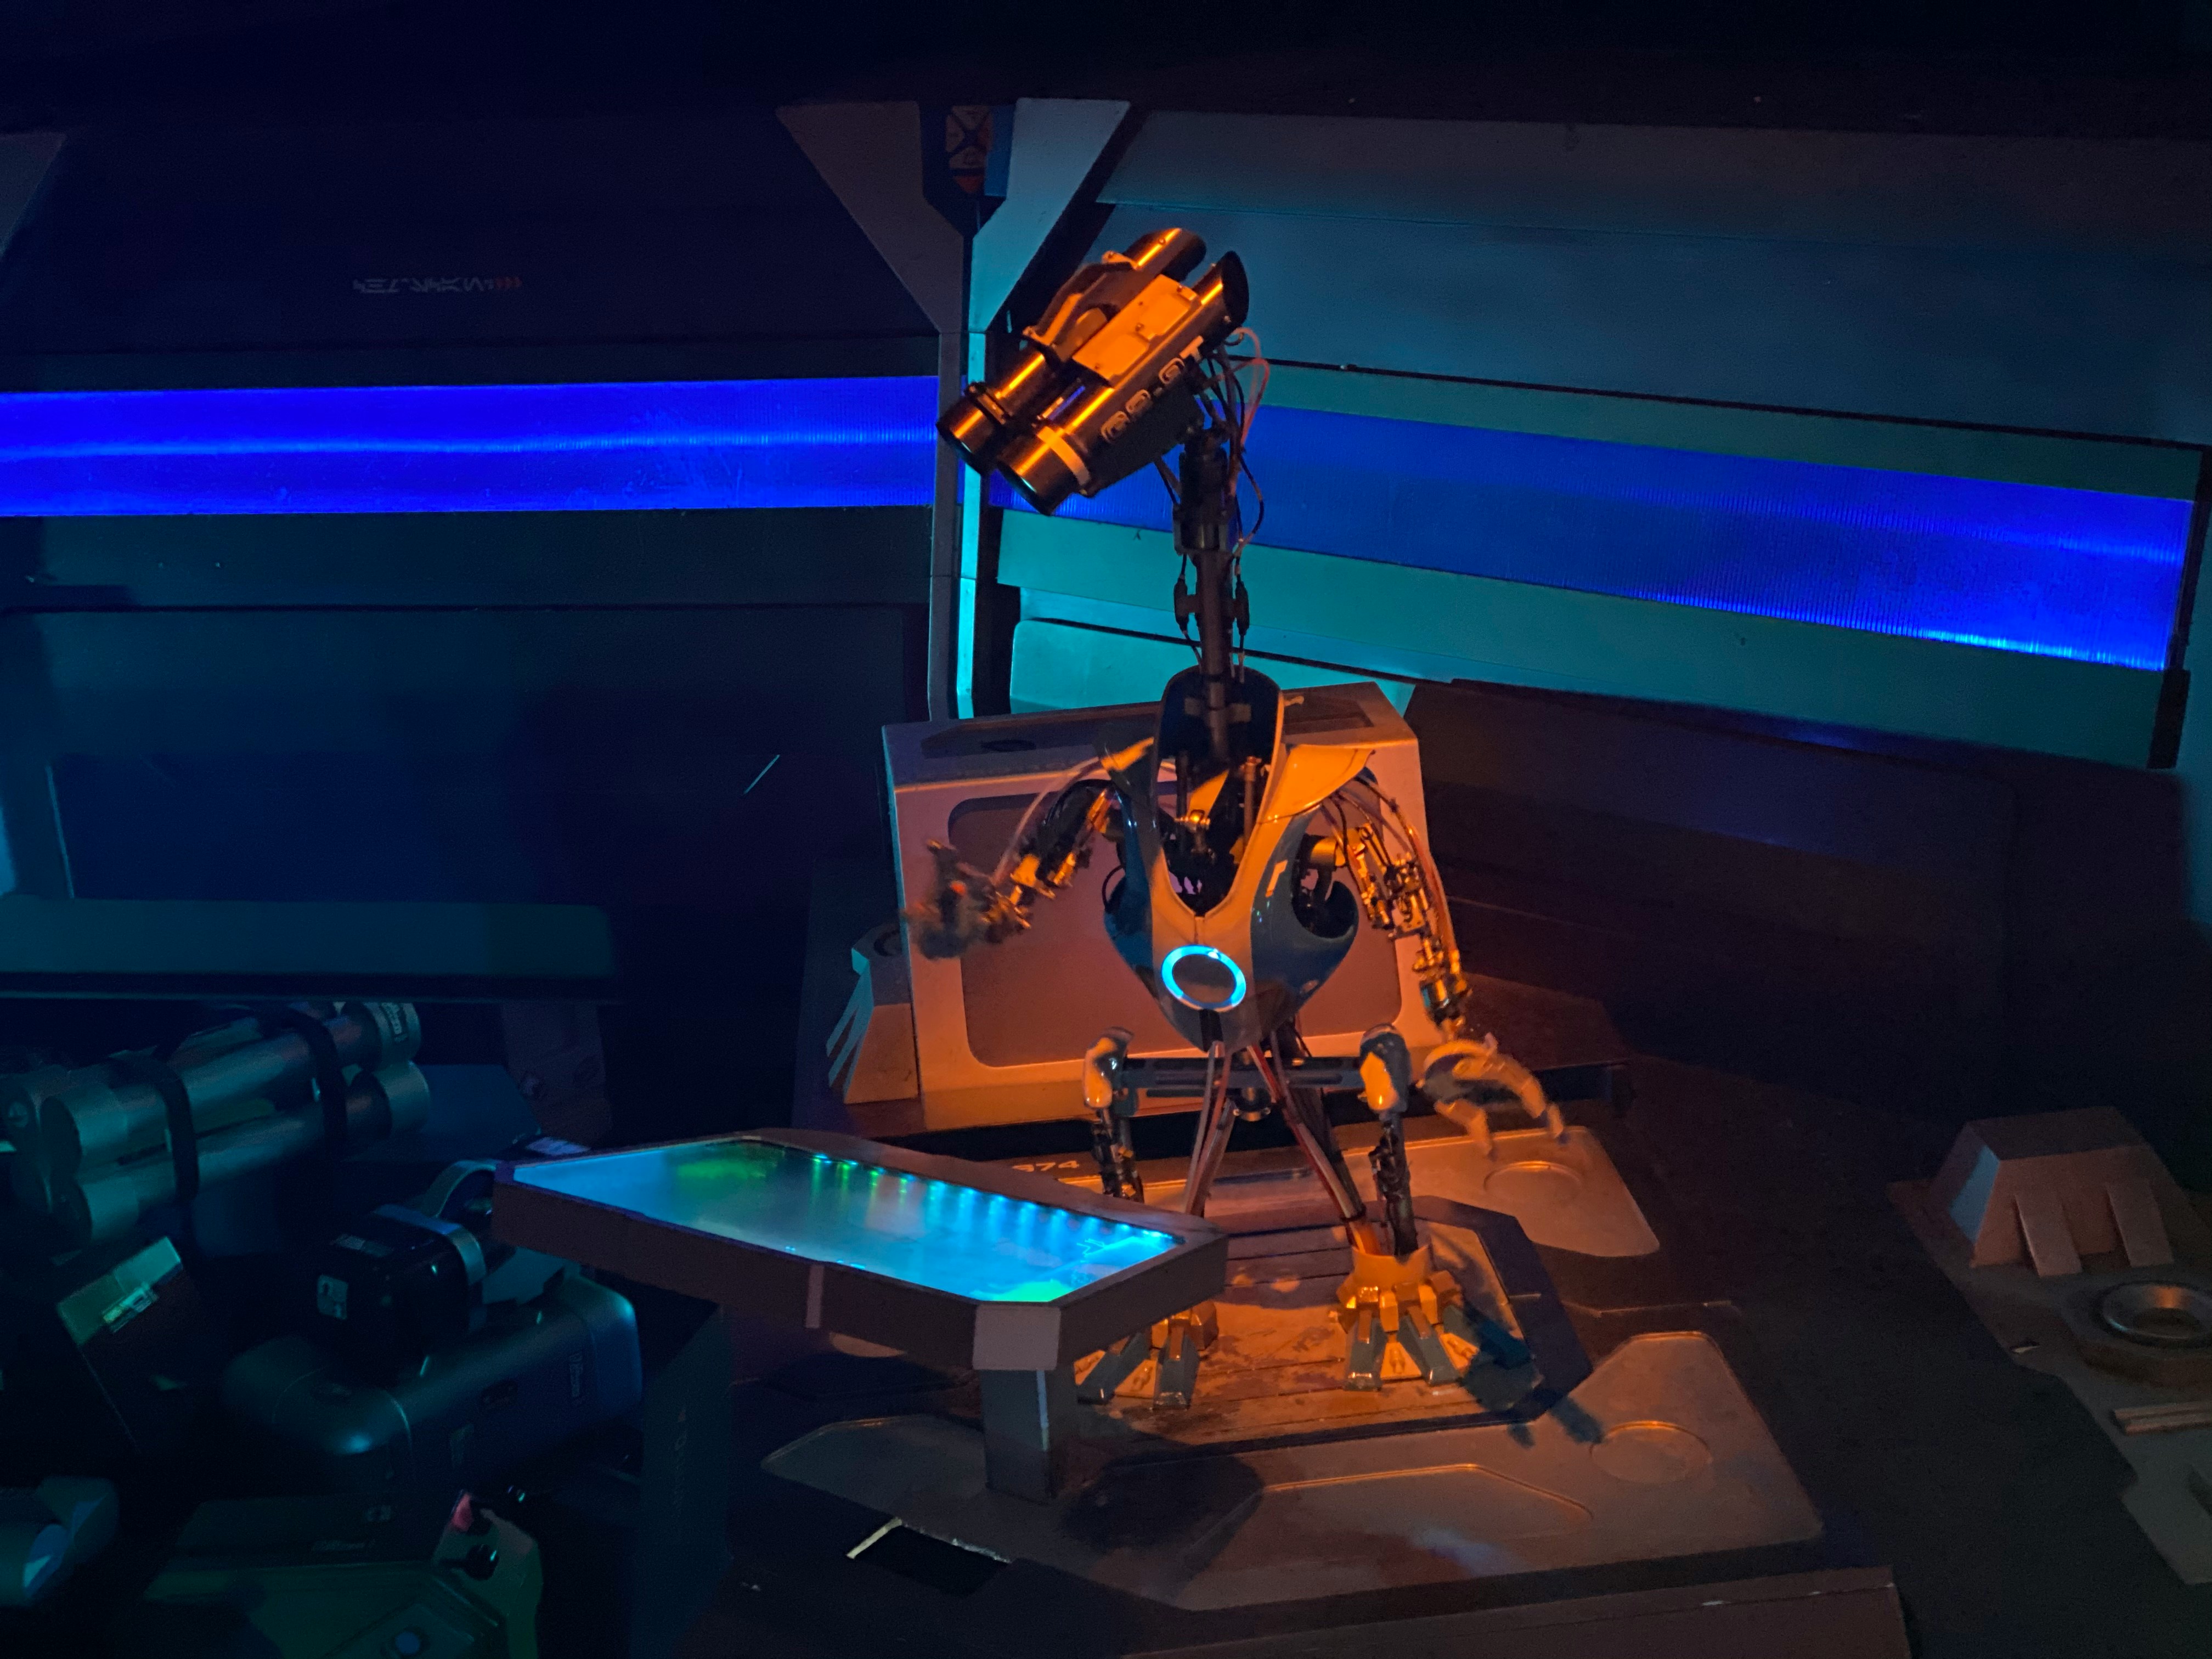
Grant built an inference-time pipeline that makes a frozen robot policy more reliable without retraining. The policy samples multiple candidate action chunks. A 62M-parameter learned world model predicts the future trajectory each candidate would produce. Similar predicted futures are grouped, and the robot executes an action from the largest supported mode.
What Worked
World-model-guided selection raised eight-task real-robot success from 66.8% to 87.5%, improving every task over the frozen policy.
What Has Been Achieved
On an eight-task real-robot benchmark, success rose from 66.8% to 87.5%, improving every task.
What Was Learned
Training new skills by reinforcement learning inside the learned world model failed because policies exploited errors in its predictions. In this project, using the world model for inference-time selection proved much more robust than optimising a policy through it.
About
Ed holds a PhD in Computer Science from UCL and was previously co-founder and CSO of Rahko (acquired by Odyssey Therapeutics), a quantum machine learning company. He subsequently became Head of Machine Learning at Odyssey Therapeutics.
Lab & Advisors
Dimitrios Kanoulas
University College London
Professor of Robotics and AI; UKRI Future Leaders Fellow
Dimitrios Kanoulas is Professor of Robotics at University College London (UCL), where he leads research on robot perception, cognition, and learning for intelligent machines operating in unstructured and uncertain environments. His work focuses on enabling highly articulated robots, such as legged robots, to perceive, navigate, and interact safely and effectively in complex natural terrains. Robotics has the potential to improve safety, health, and comfort in society, and his research advances this vision by developing cognitive systems that allow robots to sense, adapt, and make decisions in dynamic real-world settings.
Lorenzo Jamone
Associate Professor in Robotics & AI at UCL Department of Computer Science
Lorenzo Jamone is Associate Professor in Robotics and AI at the Department of Computer Science of University College London (UCL), where he leads the CRISP group: Cognitive Robotics and Intelligent Systems for the People. The main focus of the group is on researching the "intelligence of the hand", aiming to create dexterous robotic systems that can use their hands as smartly as humans do, but also to better understand the cognitive processes behind human dexterity through the use of robotic technologies and computational models. This research has generated over 140 publications (H-index 31) in the areas of cognitive robotics, robot learning, robotic manipulation, and tactile sensing.